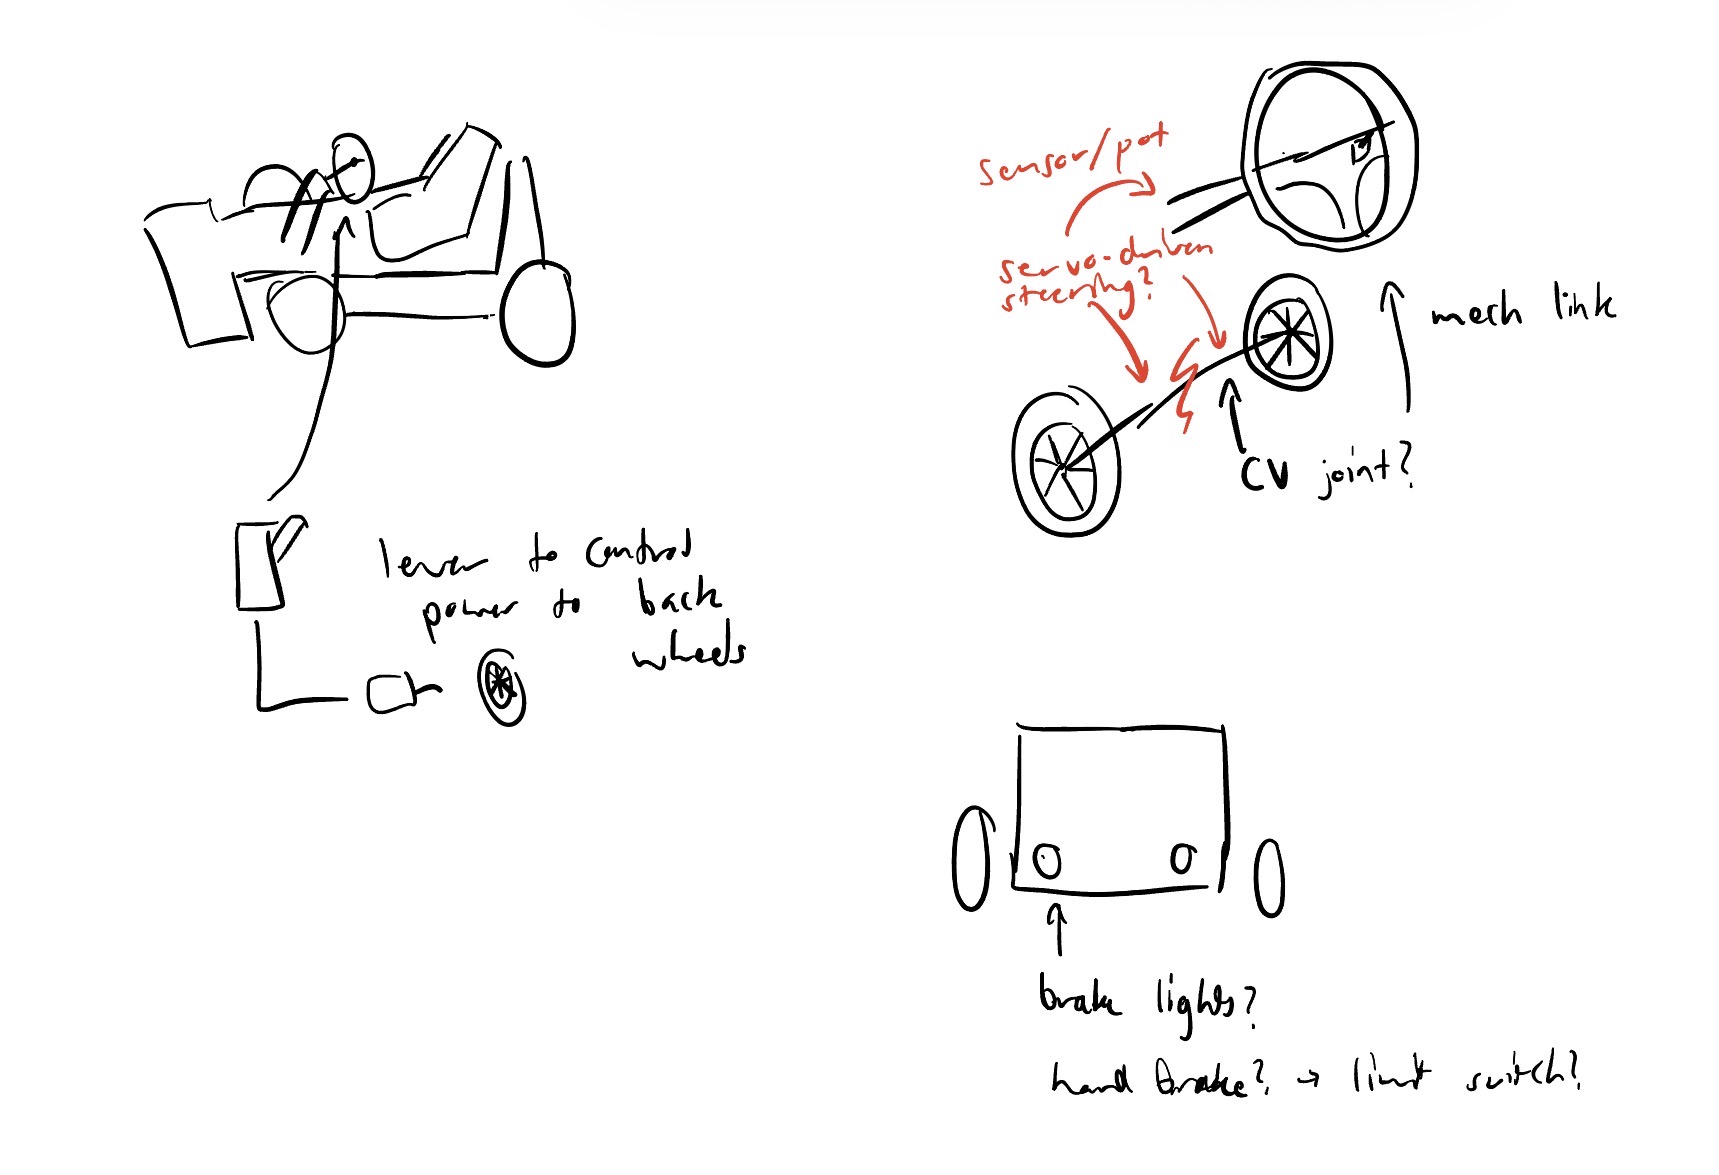
My first big idea for a final project was building a functioning go kart. My main doubts in doing this would be some of the heavier
mechanical parts. How would I make tires? How heavy do the axles need to be? Do I need complex mechanical linkages for steering?
If push comes to shove, I can buy some of these parts.
Sub-Idea 1: Program a potentiometer or some nicer sensor to pick up steering wheel location and convert that into servo actuation
of the front wheels. This would allow me to smooth out output with an algorithm, but may require powerful servos.
Sub-Idea 2: I likely don't want to deal with hydraulics for braking, but if I want to be safe/street-legal, I should have
brake lights, so some sort of limit switch design on a hand brake would combine the best of both of those requirements. It depends
on how I design the brake, because the simpler the brake, the harder it will be to find room for a useful limit switch.
Sub-Idea 3: Try to keep it simple on the mechanics for acceleration. I may take inspiration from my go karts back at home
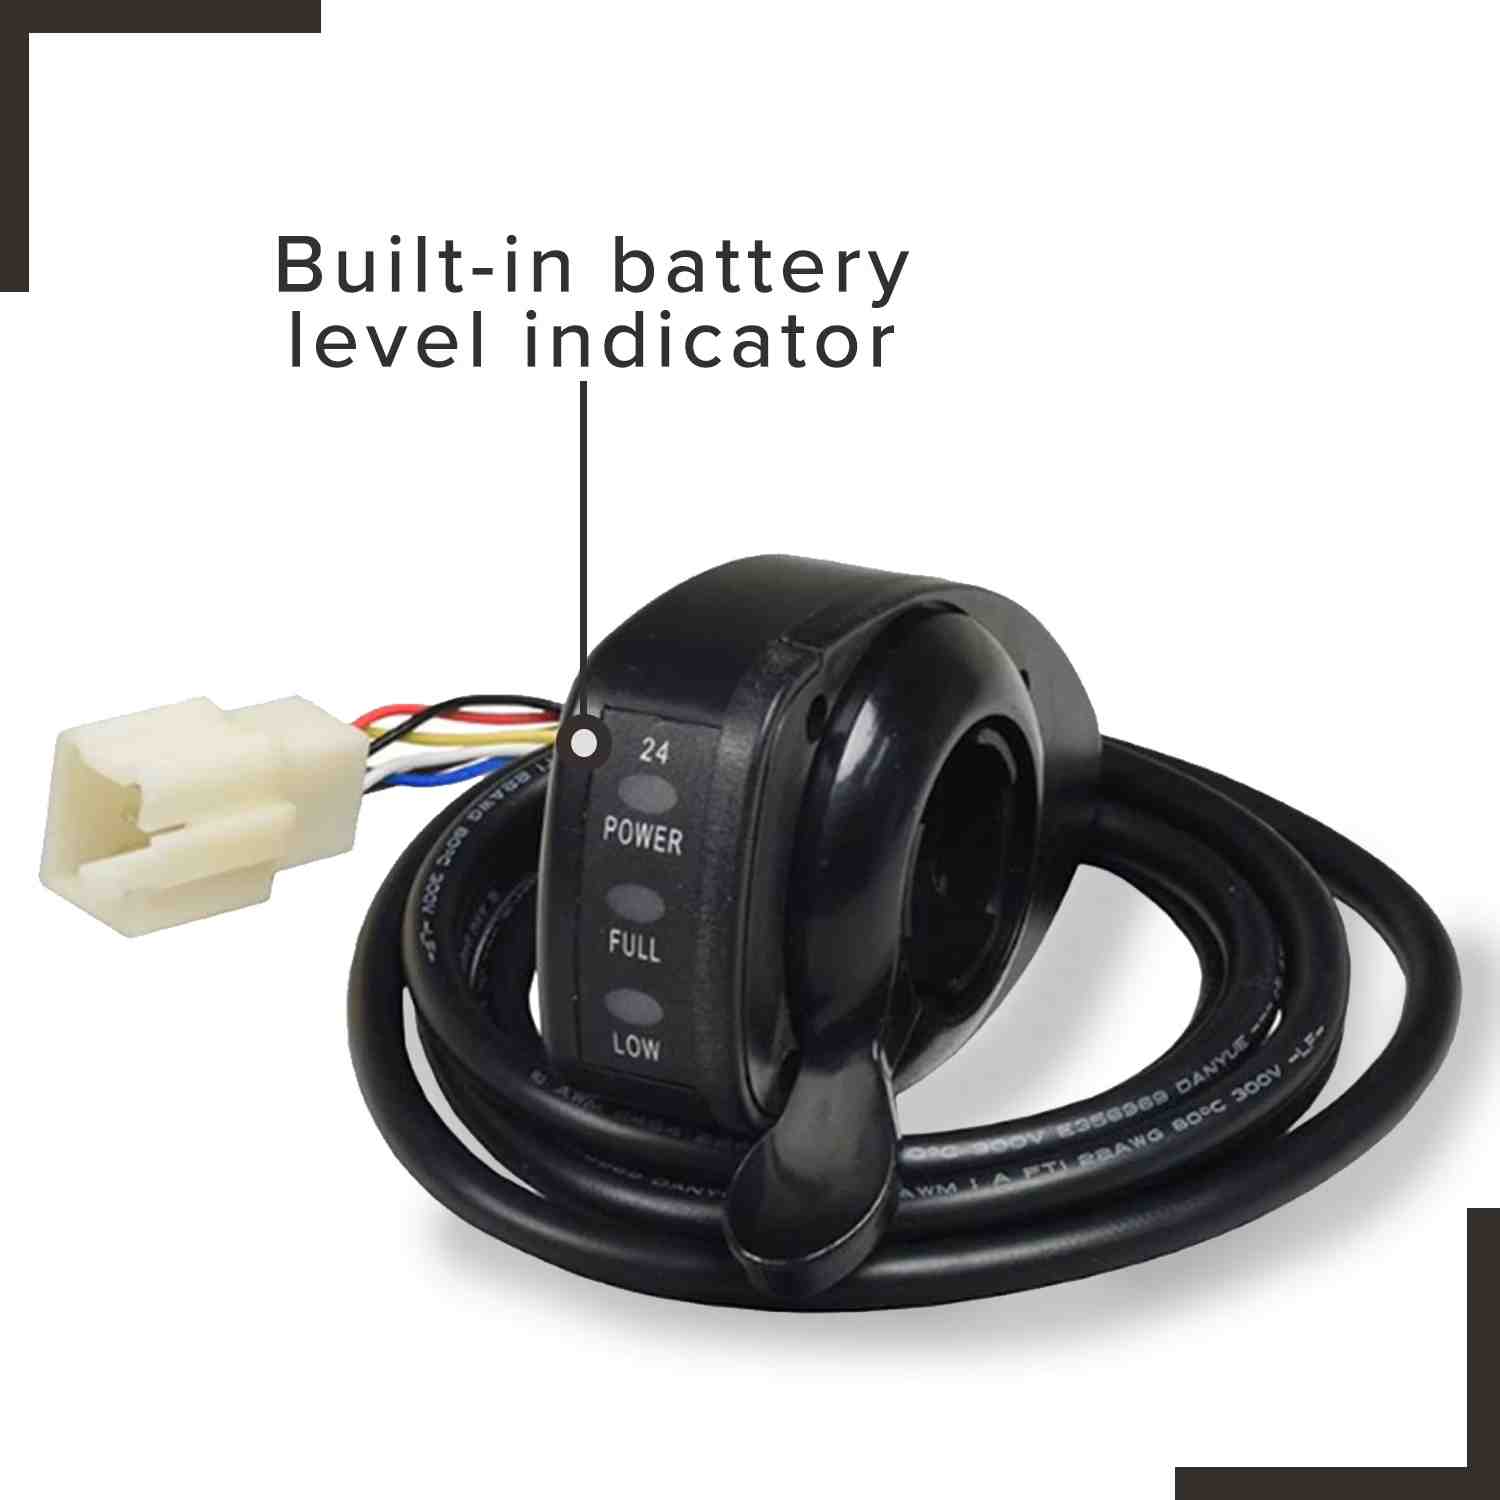
when I was a kid or the electric scooters you see all over campus and use some sort of lever throttle (see below).
This is spring-loaded, defaults to 0.
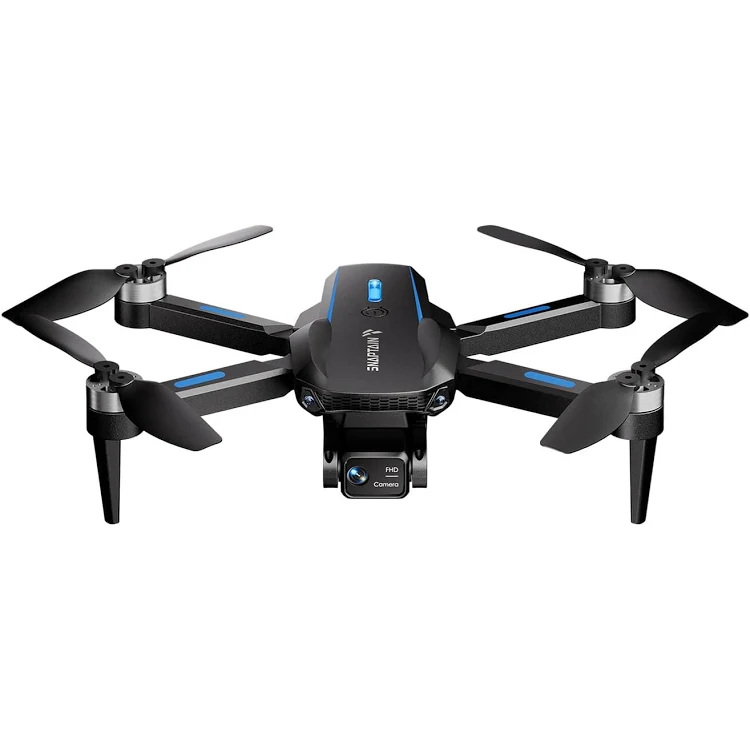
Feedback Control Drone
I would get to apply my new knowledge from my controls classes and build something that flies. This also means I would get to use an
op-amp Making a custom frame and propellers could be fun. It feels a bit overdone, though.