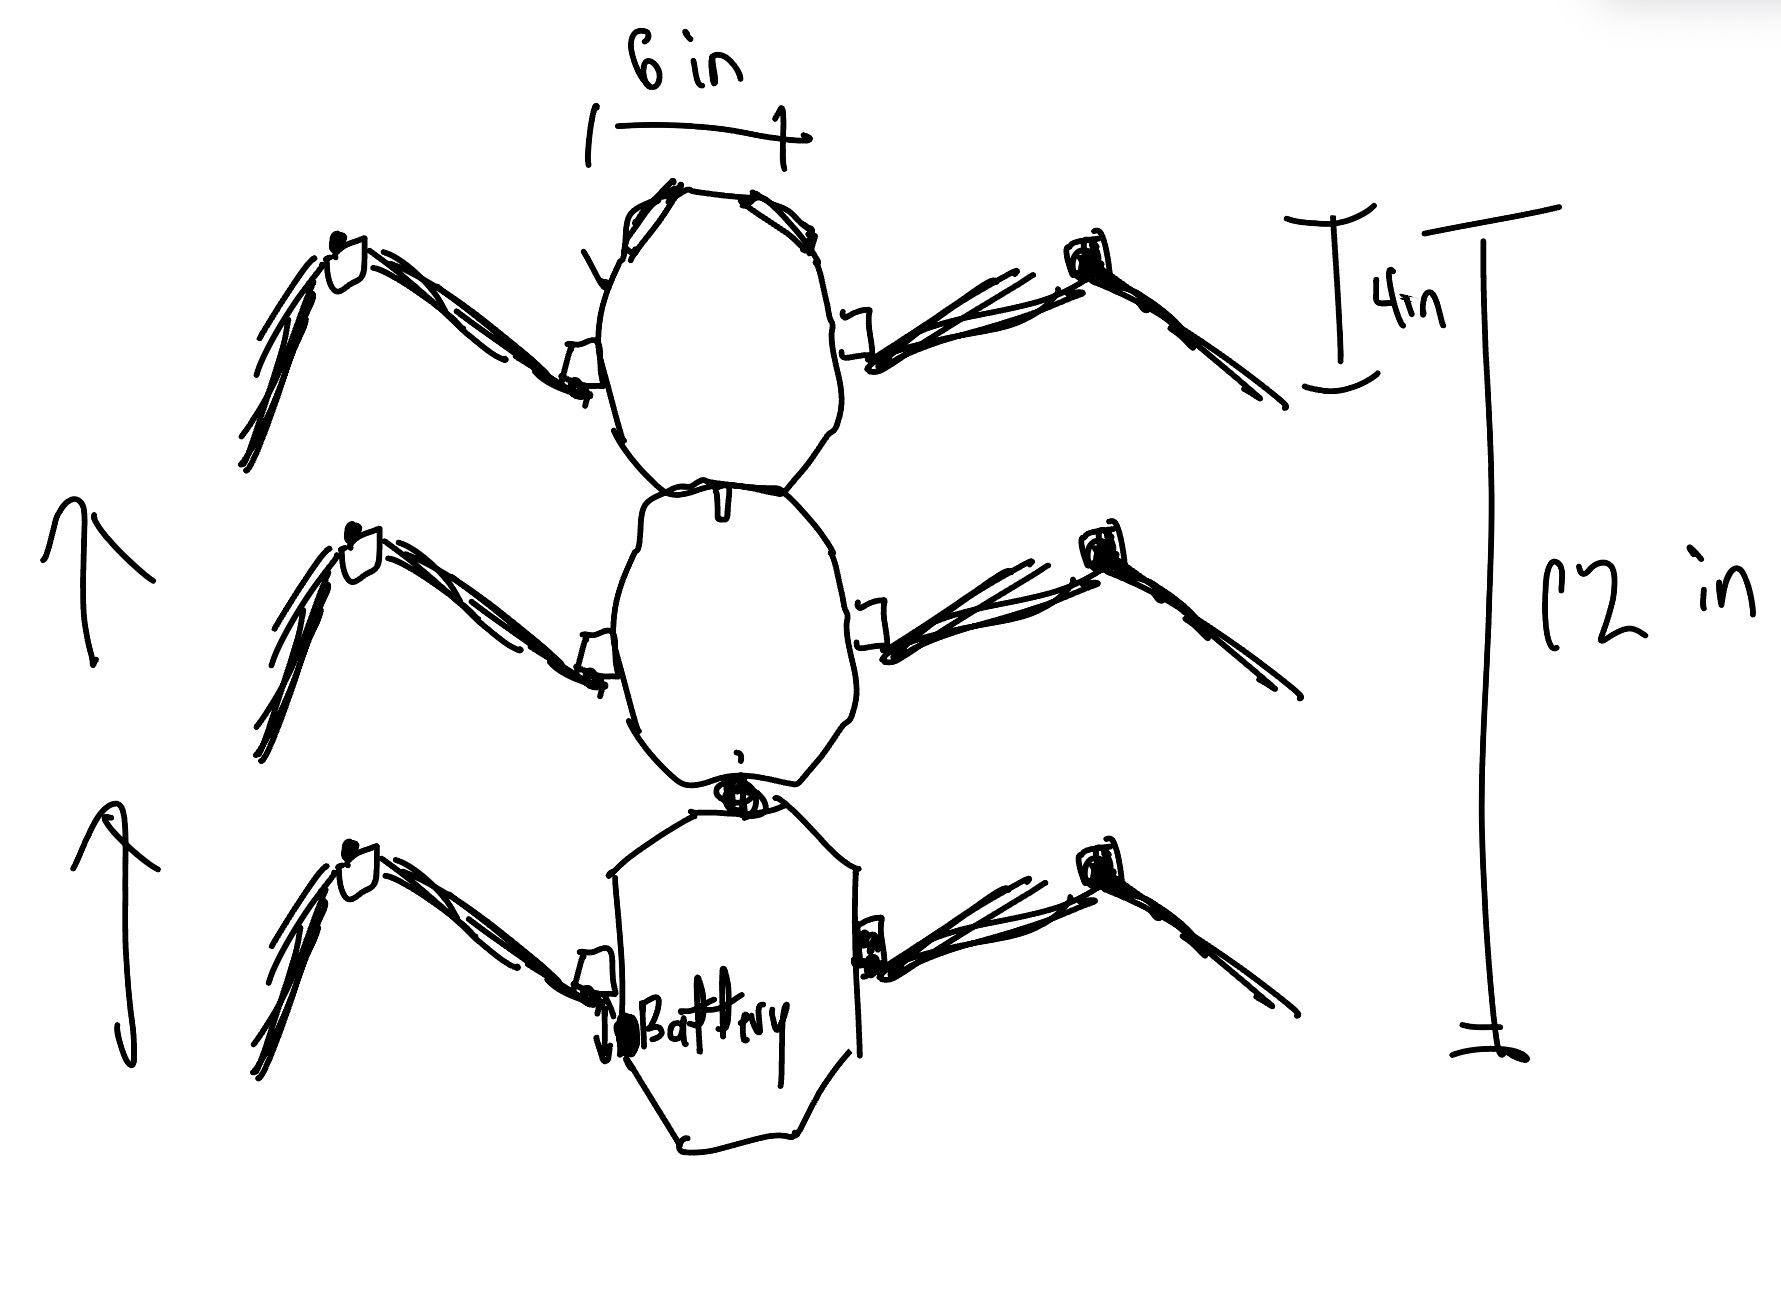
This week I decided on my final project idea: a mobile modular companion robot. The idea is a hex like robot that gains features and different abilities as the semester goes on. Initial goals for features are:
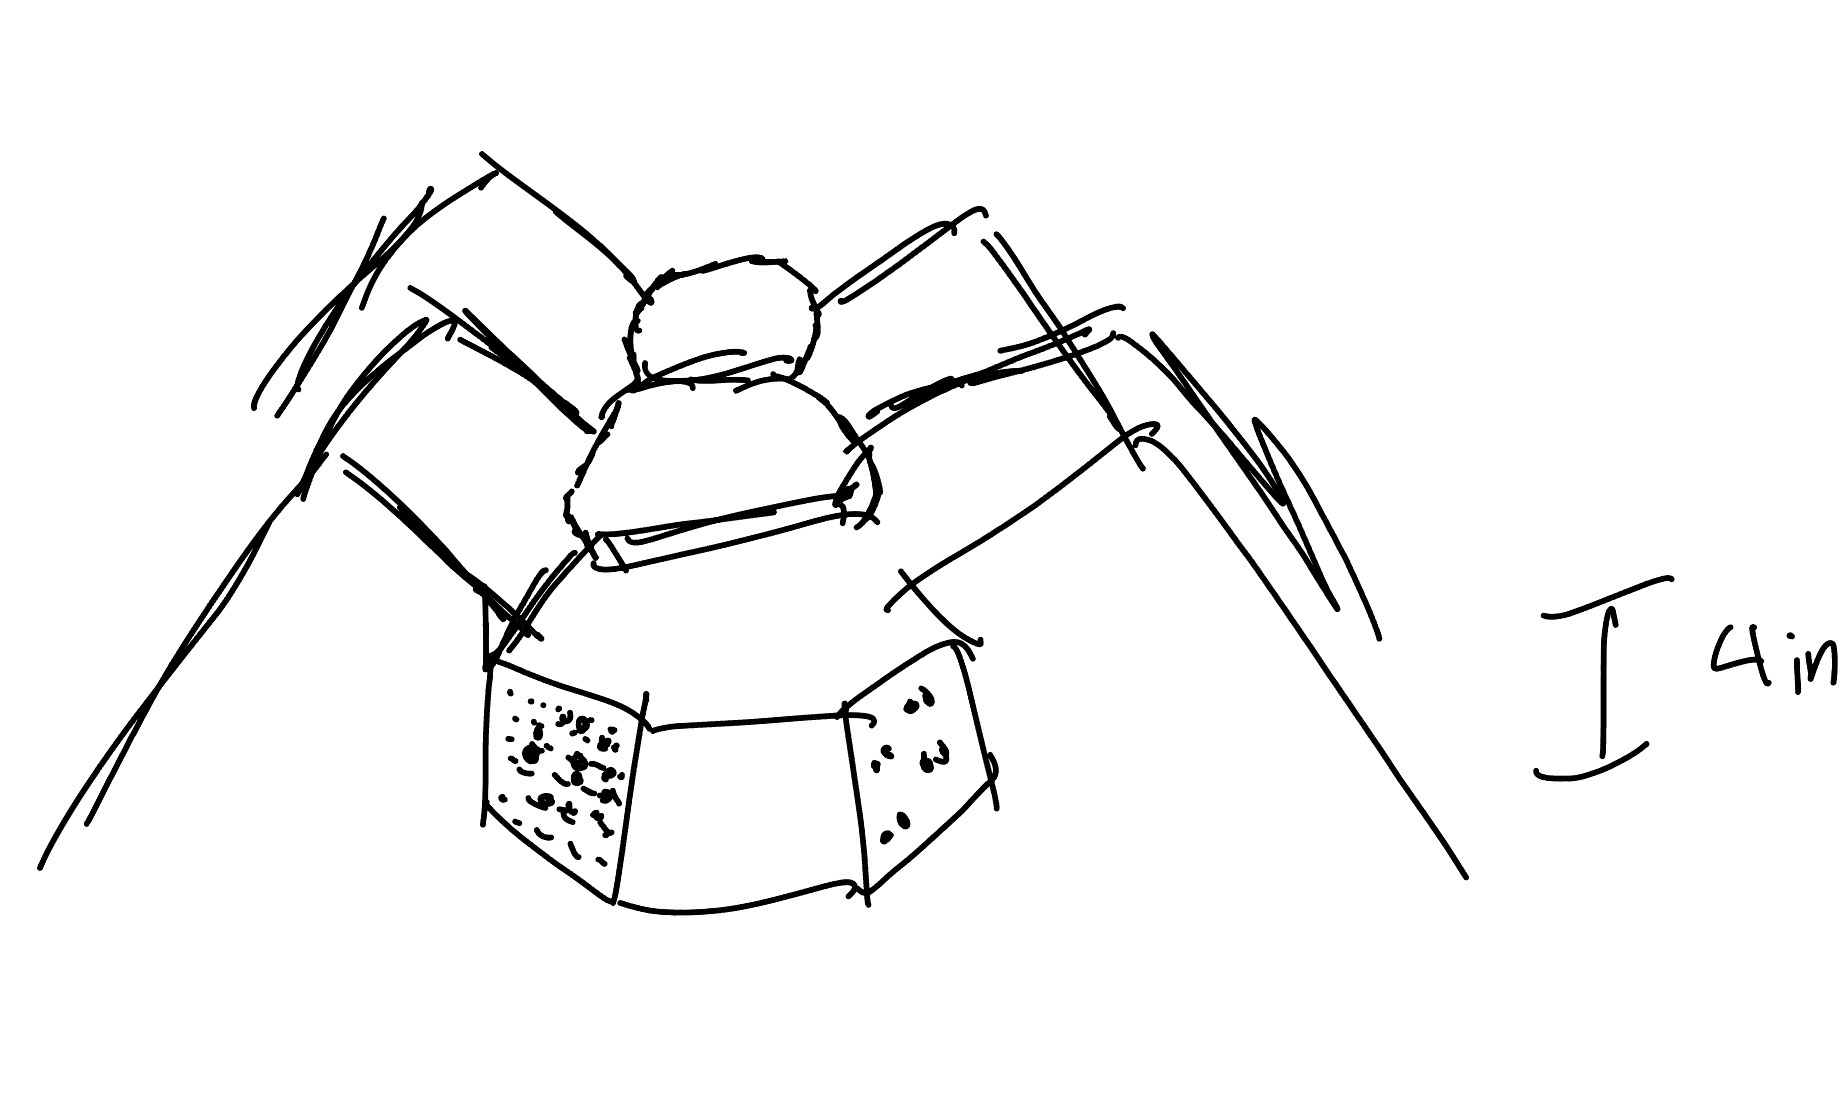
Need the design to be reasonably sturdy. Legs should be on a three axis system: One to rotate the leg back and forth, and two joints to extend the leg; one at the base, another at the "knee". A rough initial draft is included below.