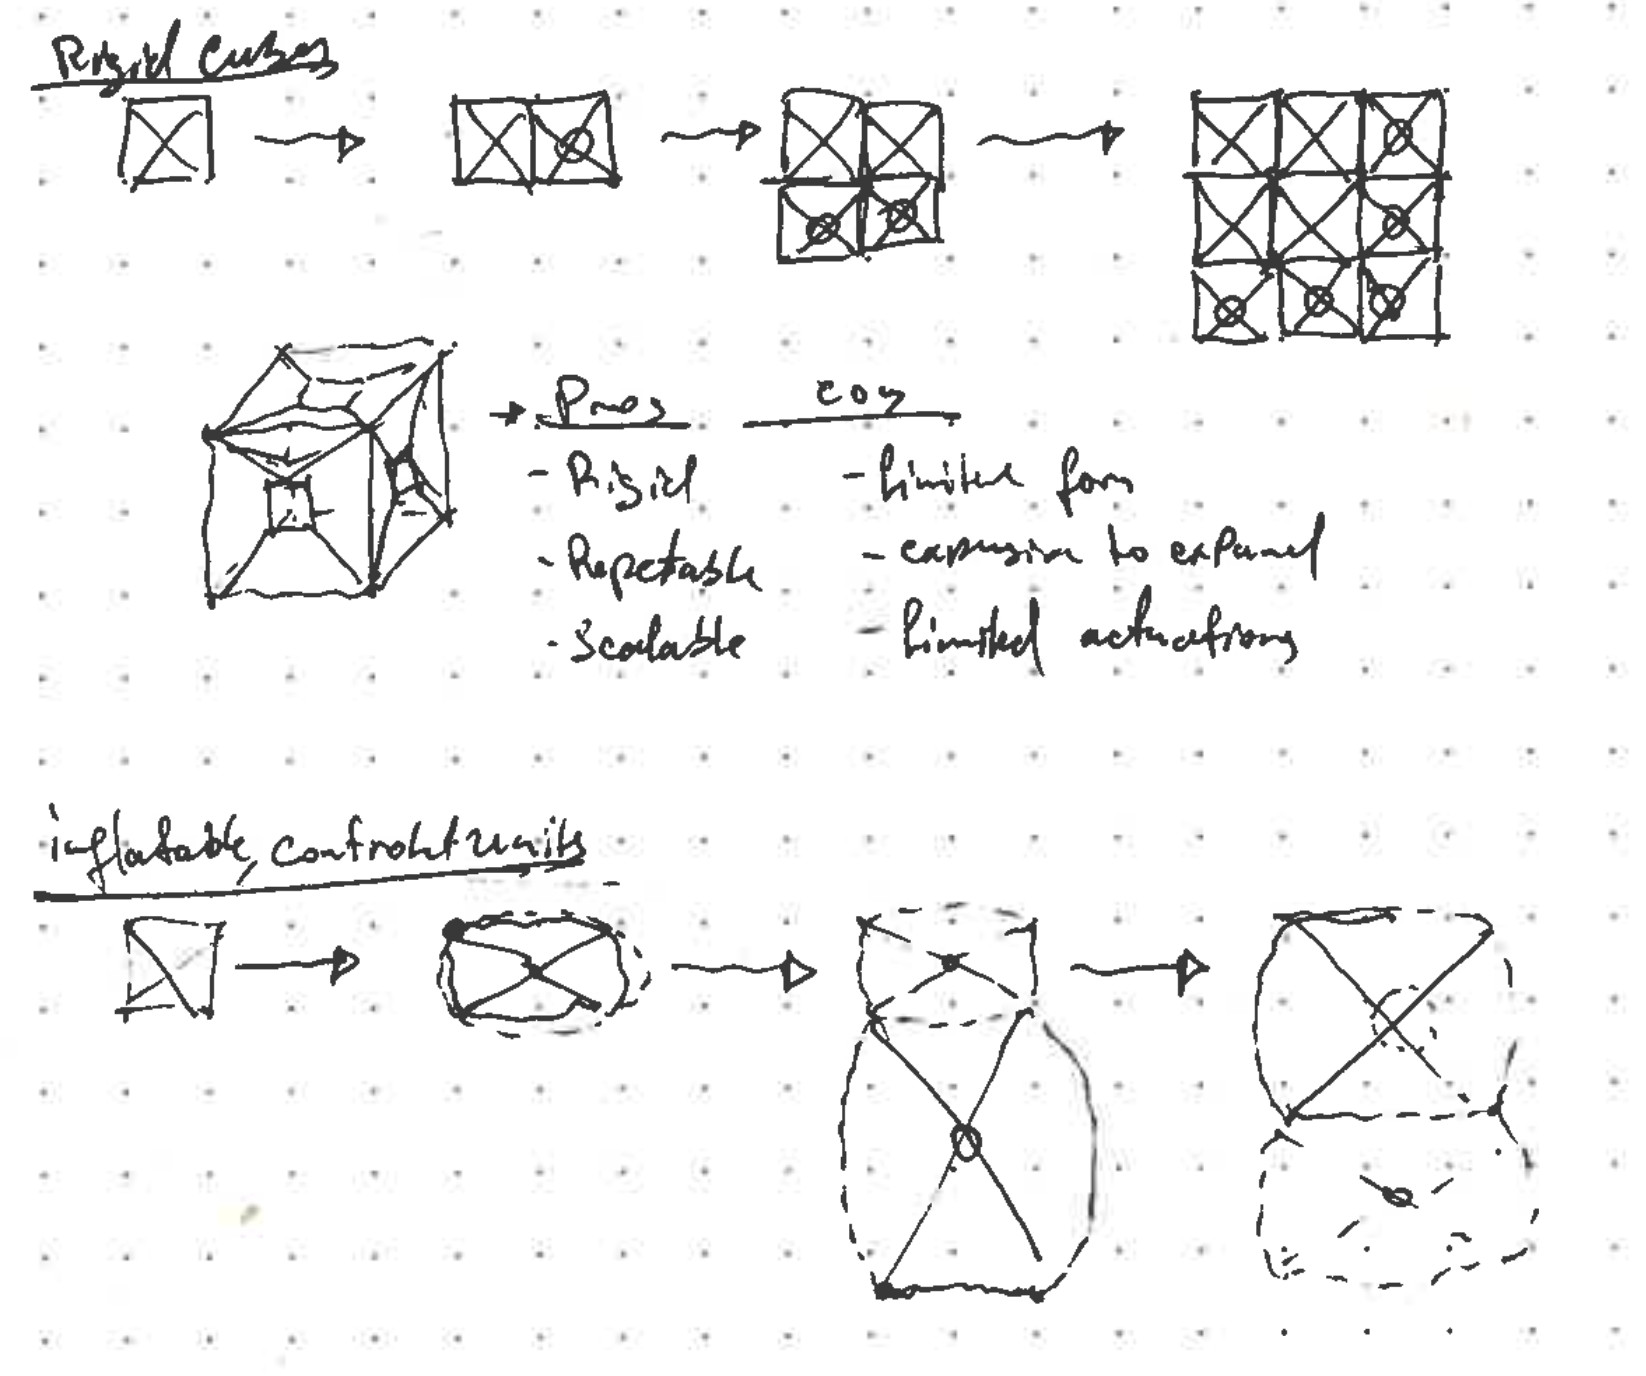
Concept
I want to build robot(s)/machine(s) inspired by Self-replicating hierarchical modular robotic swarms (figures: Abdel-Rahman et al., 2022).
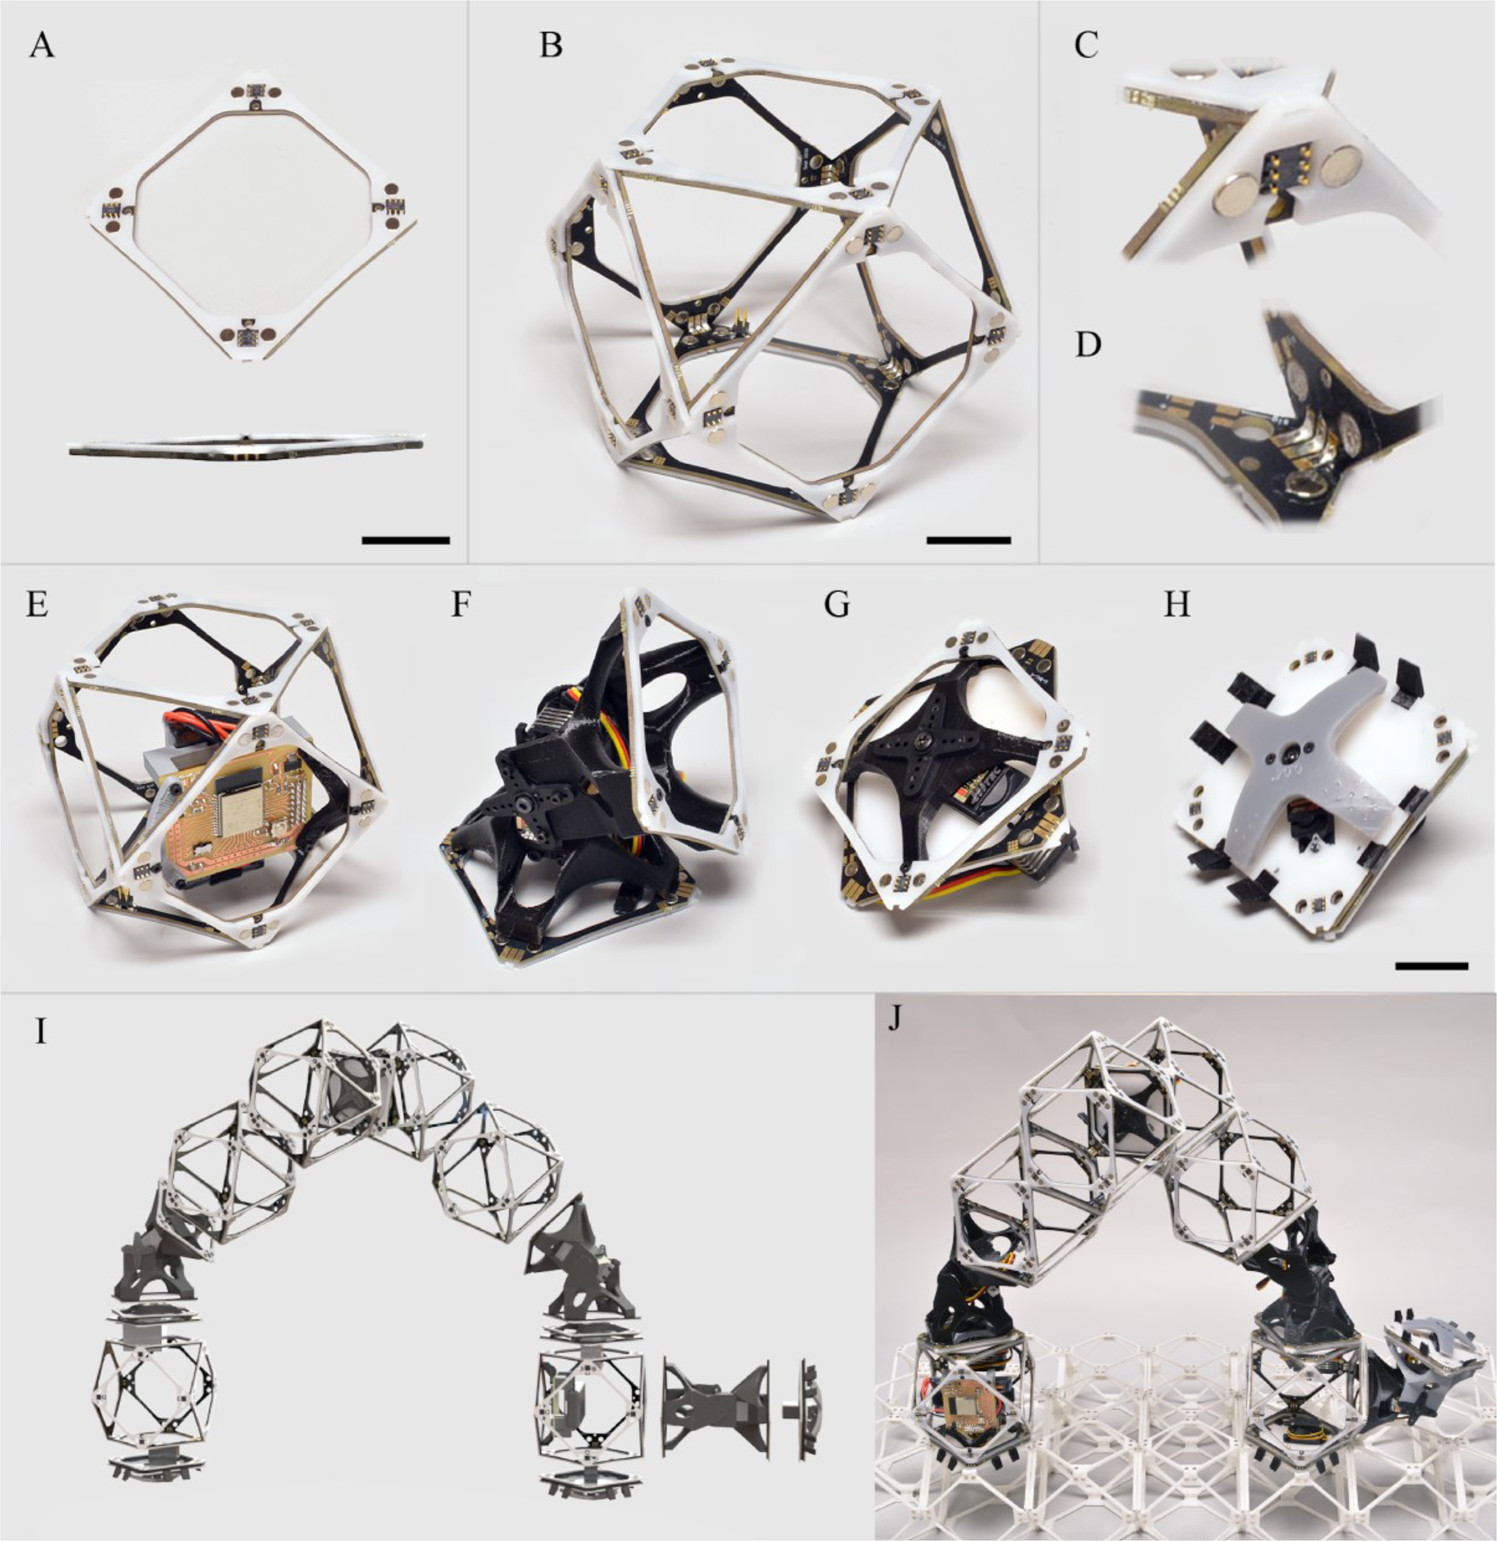
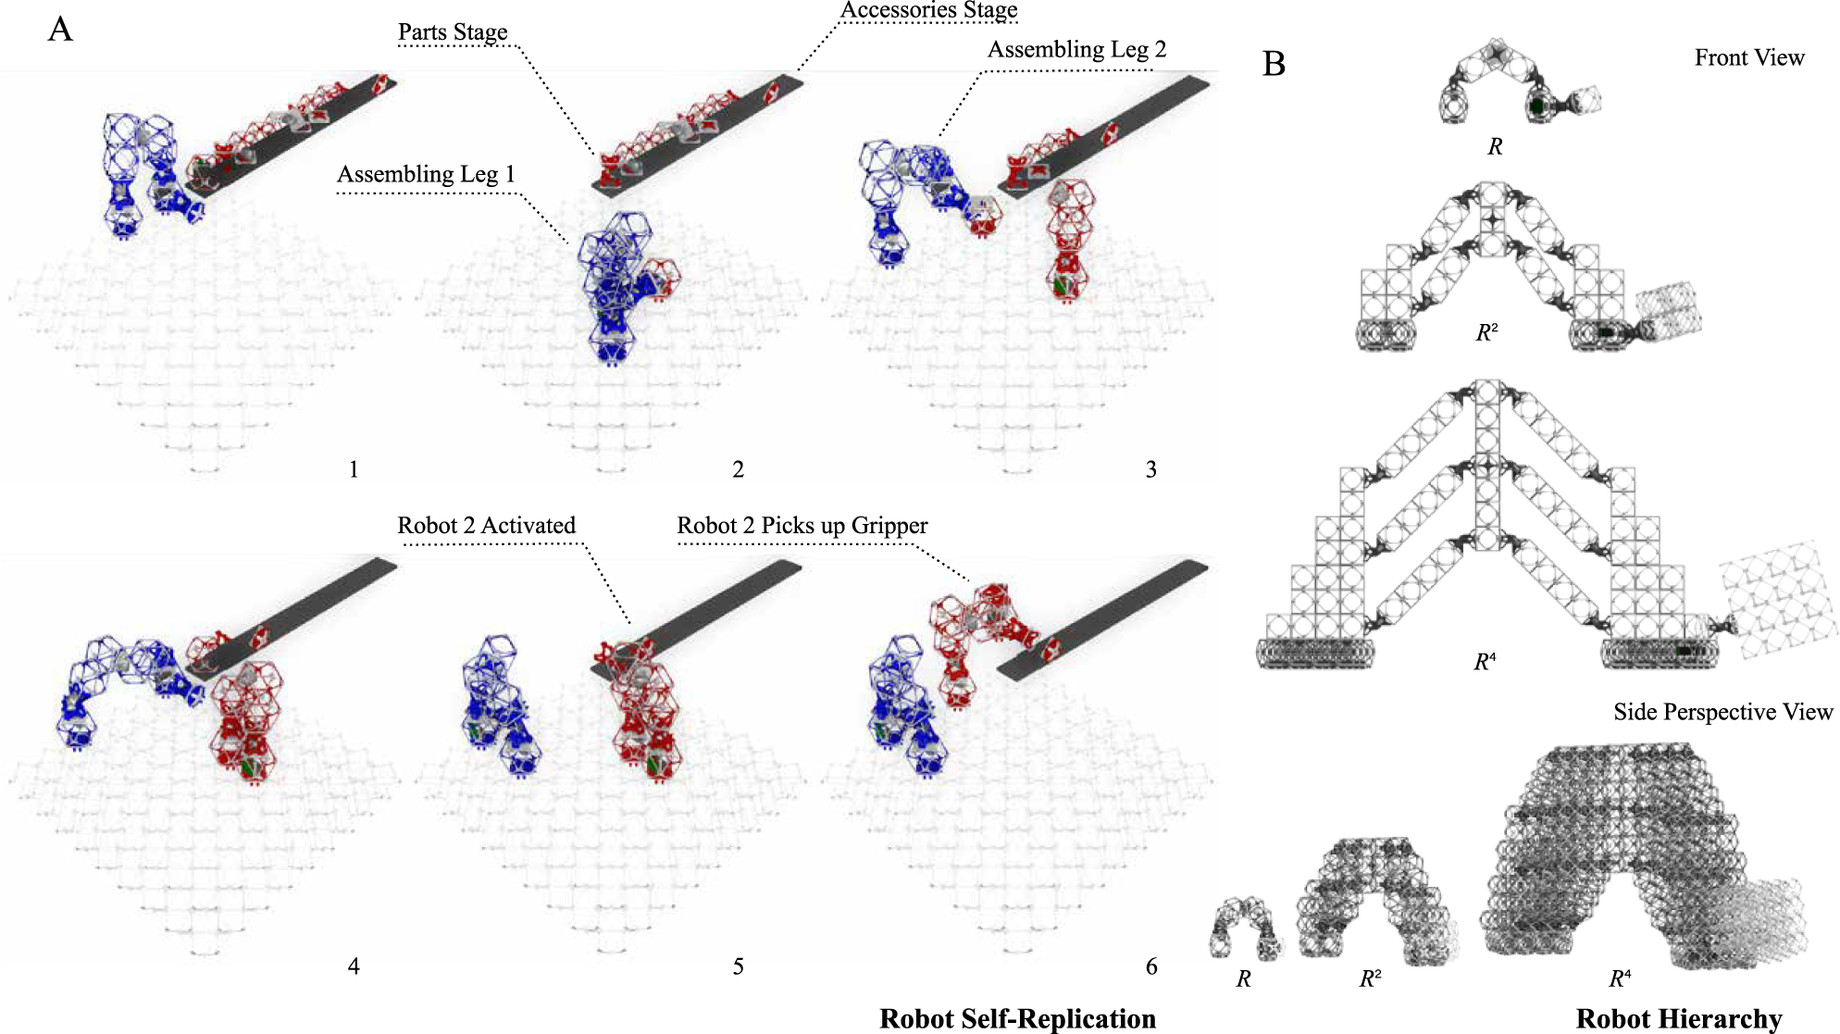
But instead of a swarm of building robots, I want to build modules that have their own intelligence, then inflate and assemble them, so that building bigger structures is faster and easier.
Each module/machine is a pneumatically activated structure with a programmable textile cover, with embedded ropes to control the form. The ropes and the textile are the control surface, and each rope has a motor with a force and position sensor on the wire roll.
Progress
09/09, week 00: the initial sketch, a soft inflatable robot structure (top).
10/07, week 04: the initial final board, a XIAO RP2040 with a load cell read through the NAU7802 ADC, and a servo header.
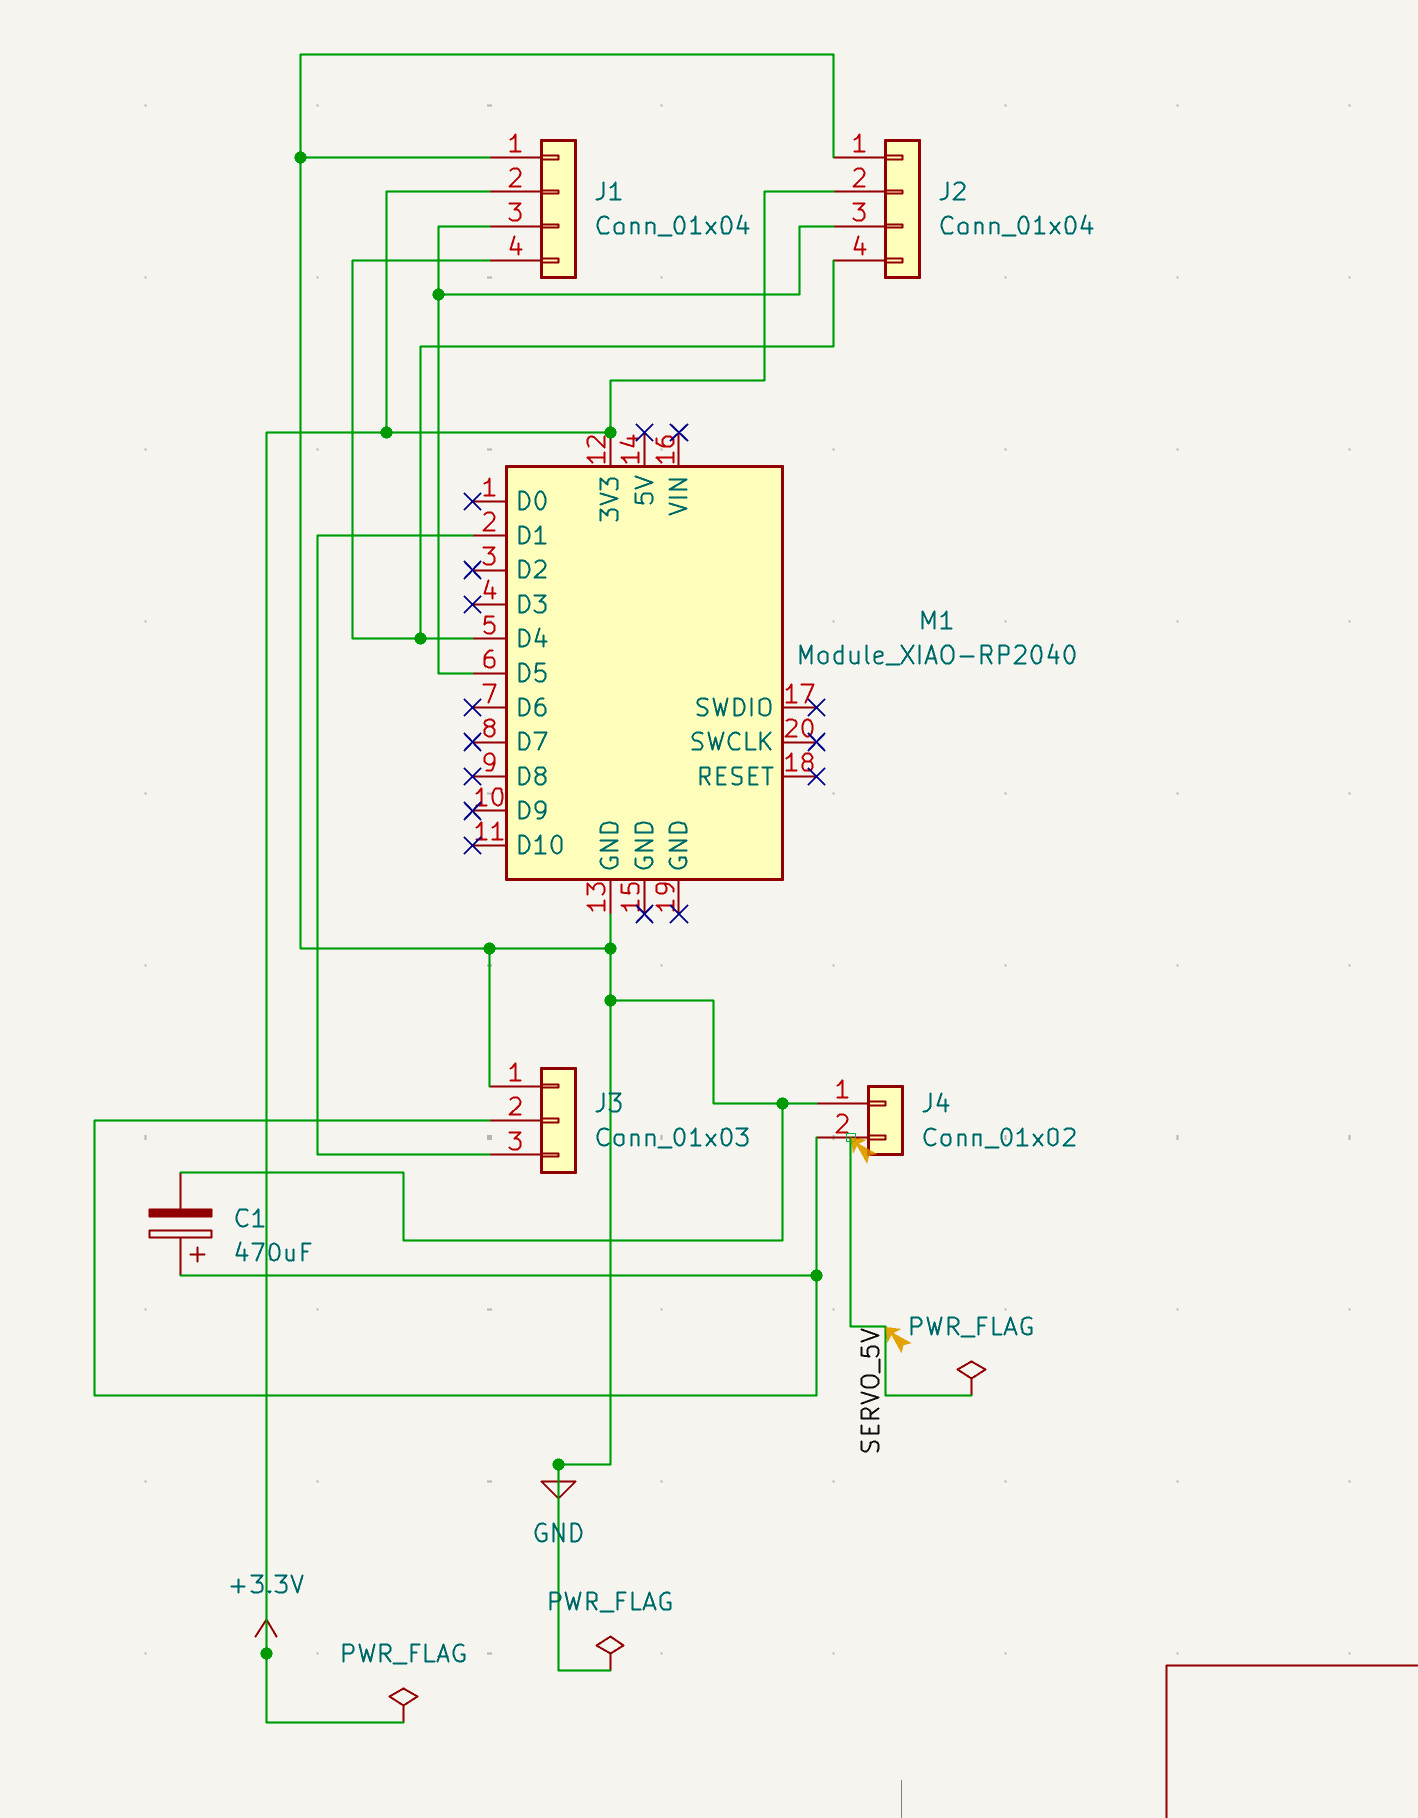
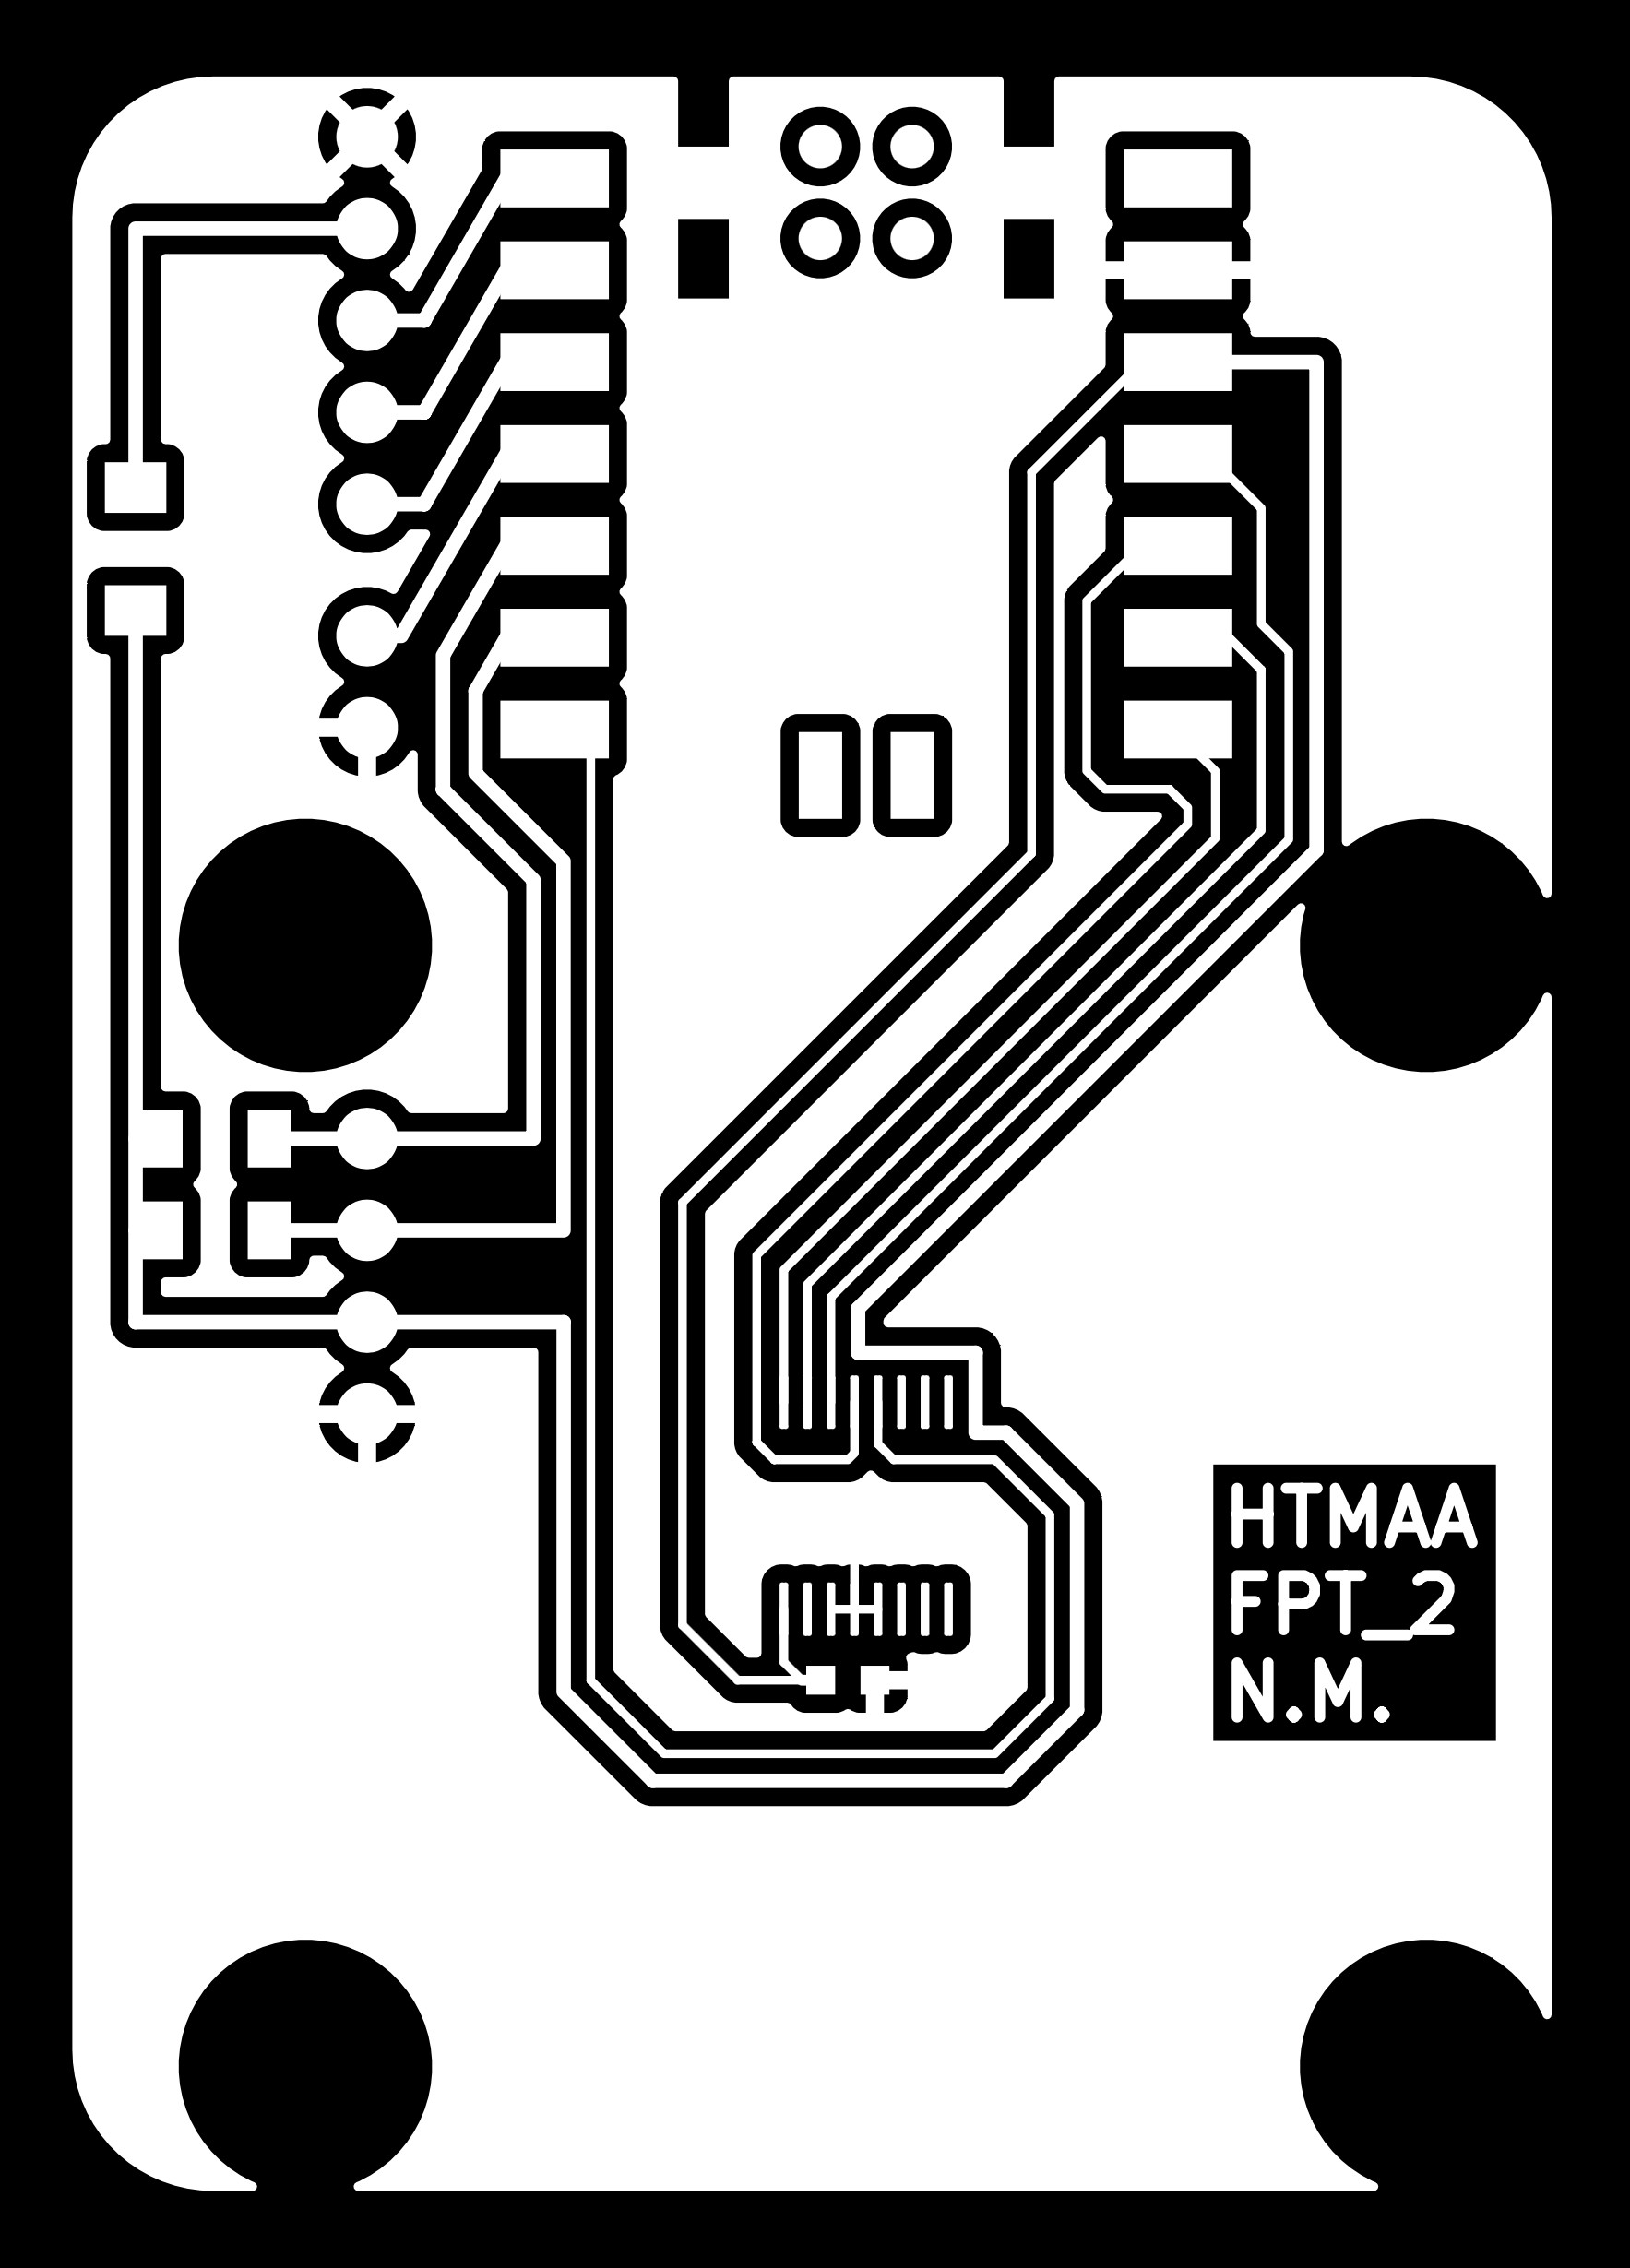
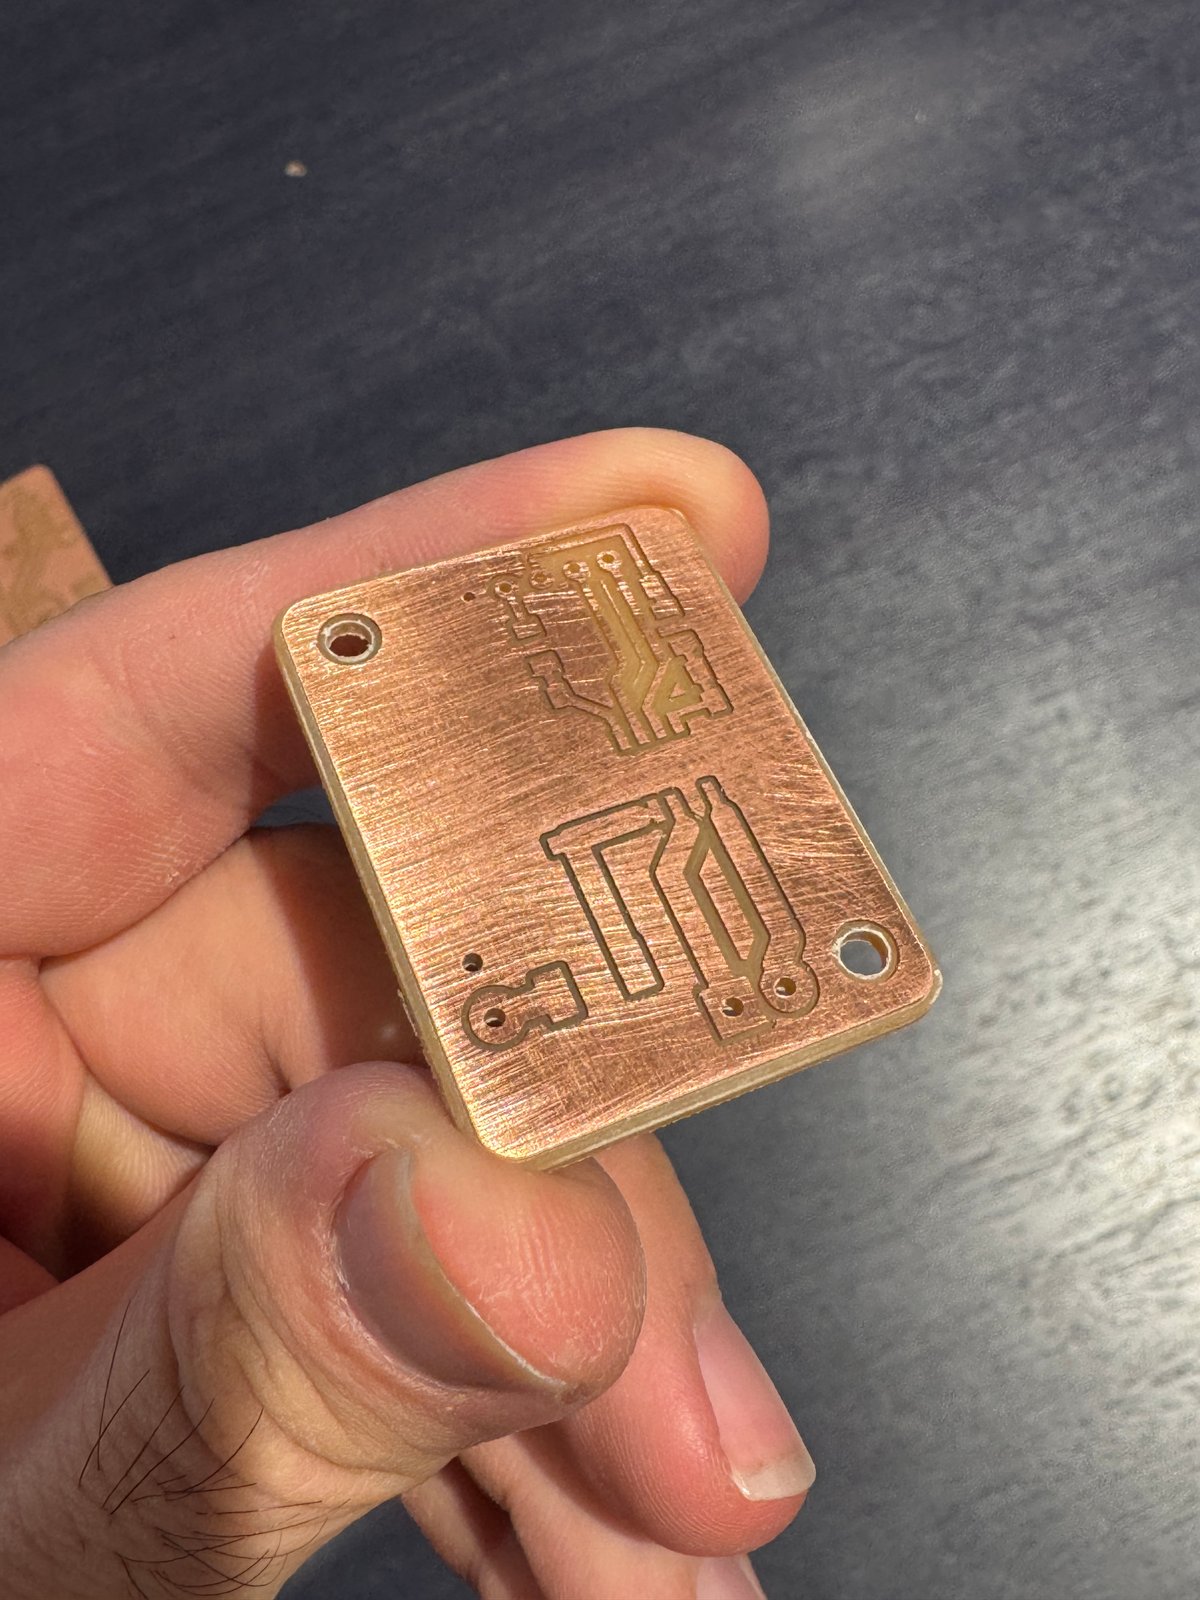
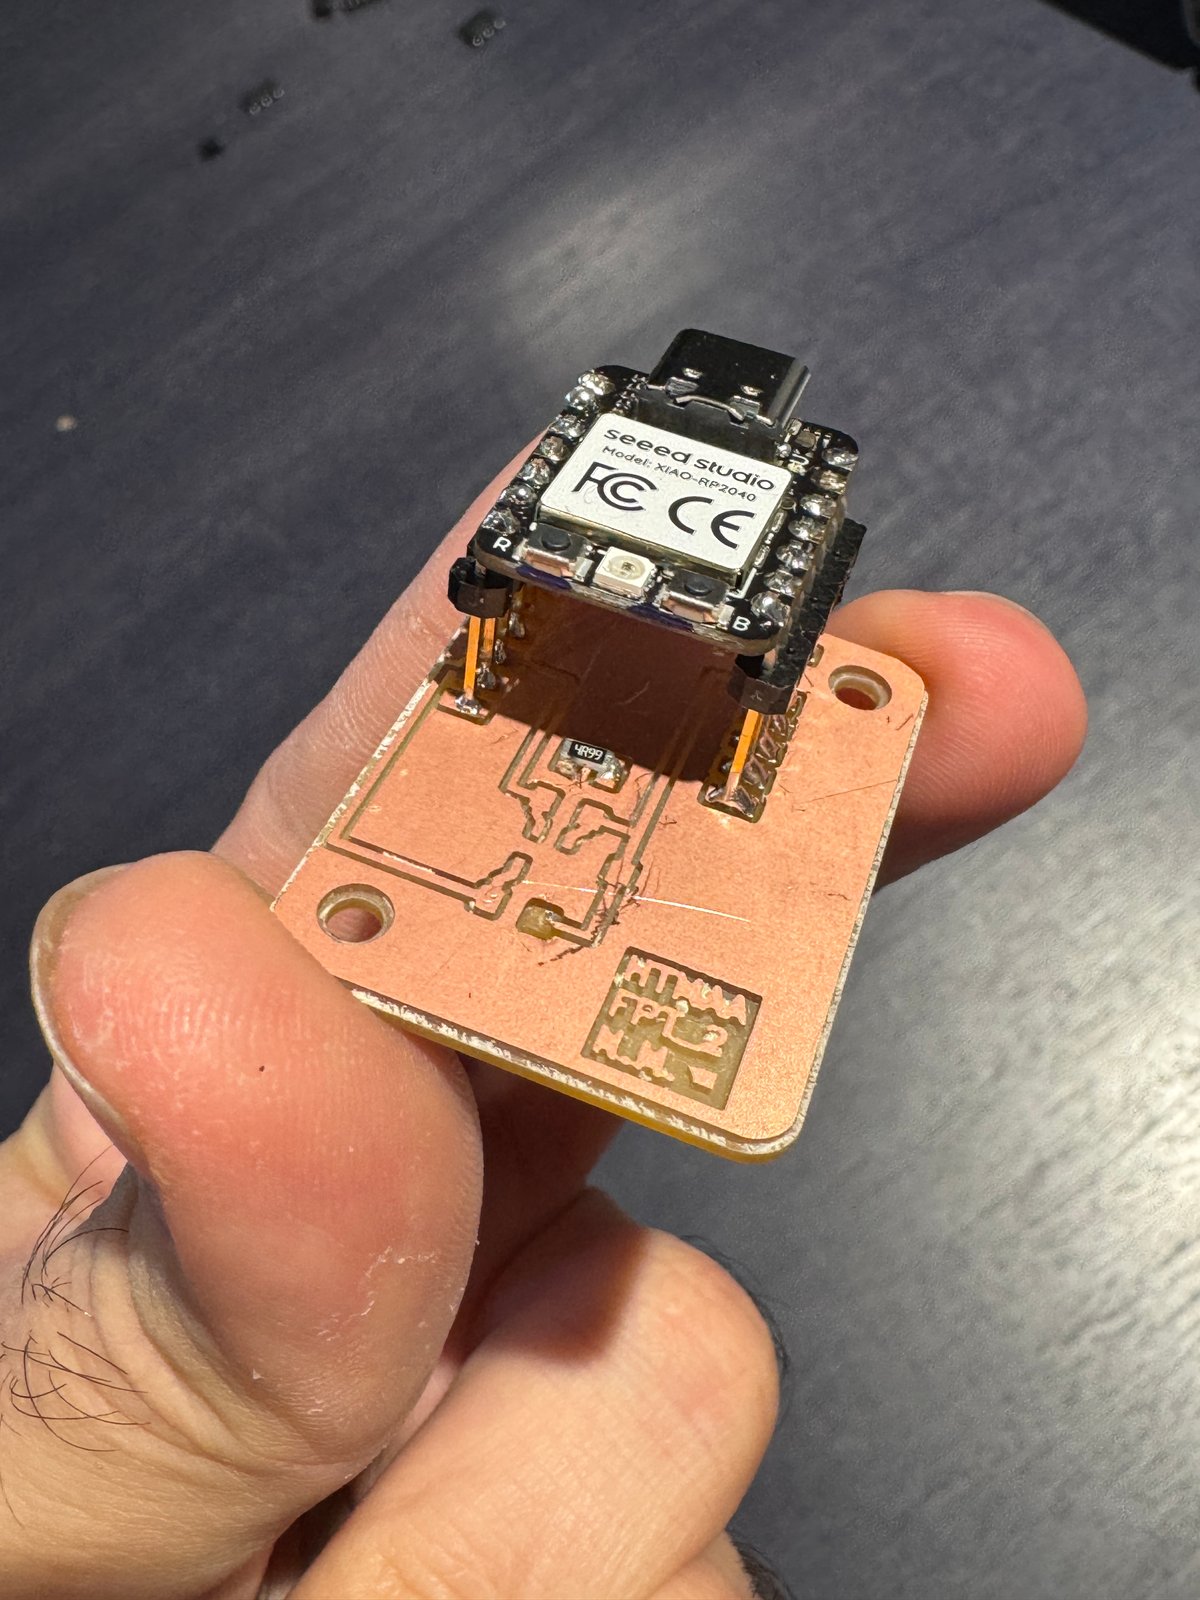
10/14, week 05: a "SIMPLE" motor with force and position sensing. A brushless motor looked great, but the ESC we have only does unidirectional rotation, and FOC controllers are too expensive for 10s of motors. So now: a simple 130-size DC motor with an H-bridge, a hall effect sensor with a diametrically magnetized magnet for the position, and a load cell for the force. Two PCBs, one with the hall sensor and the XIAO, and a small one with the H-bridge for the motor. Milled both, then fails over fails over failsss.
Reference
- Wang, Guanyun, Kuangqi Zhu, Lingchuan Zhou, Mengyan Guo, Haotian Chen, Zihan Yan, Deying Pan et al. "PneuFab: designing low-cost 3D-printed inflatable structures for blow molding artifacts." In Proceedings of the 2023 CHI Conference on Human Factors in Computing Systems, pp. 1-17. 2023.
- Abdel-Rahman, Amira, Christopher Cameron, Benjamin Jenett, Miana Smith, and Neil Gershenfeld. "Self-replicating hierarchical modular robotic swarms." Communications Engineering 1, 35. 2022.